Crash testing for robot policies
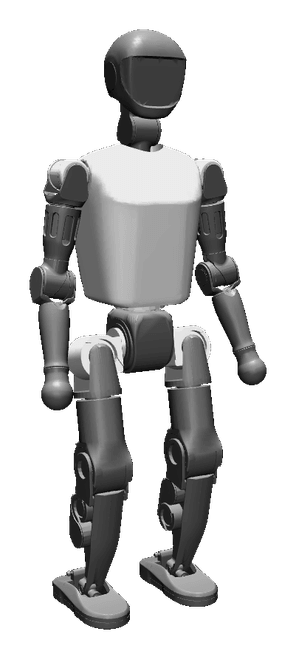
BreakPoint runs a trained walking policy through thousands of simulated conditions and shows you which ones make it fall.
Normal conditions
Same policy, same seed
Keeps walking
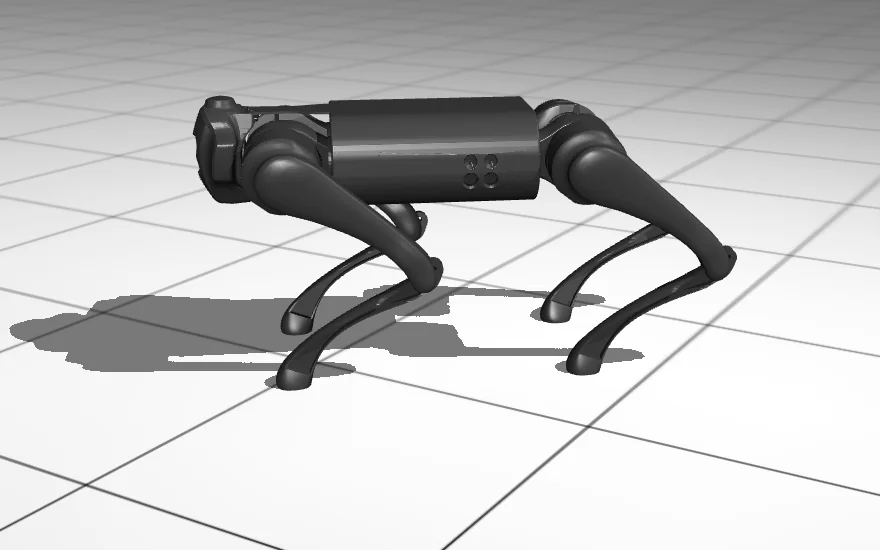 0.00 s
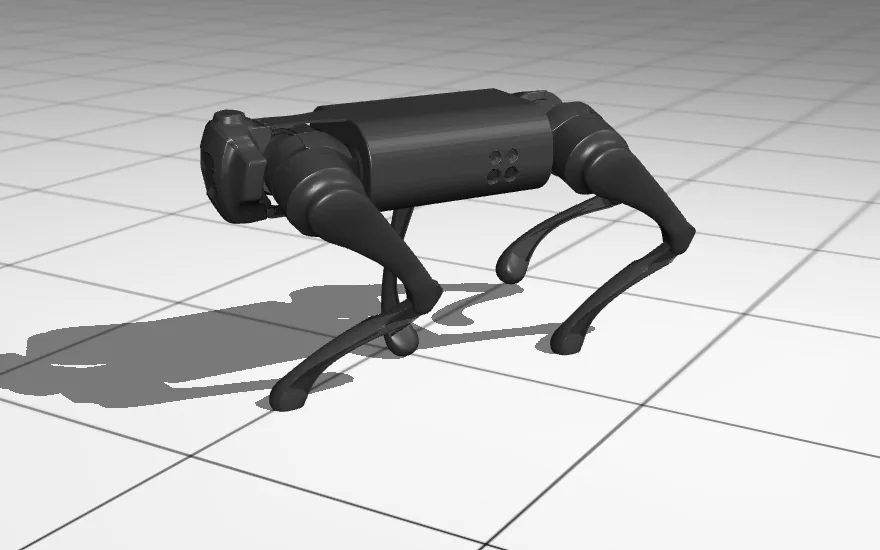 0.56 s
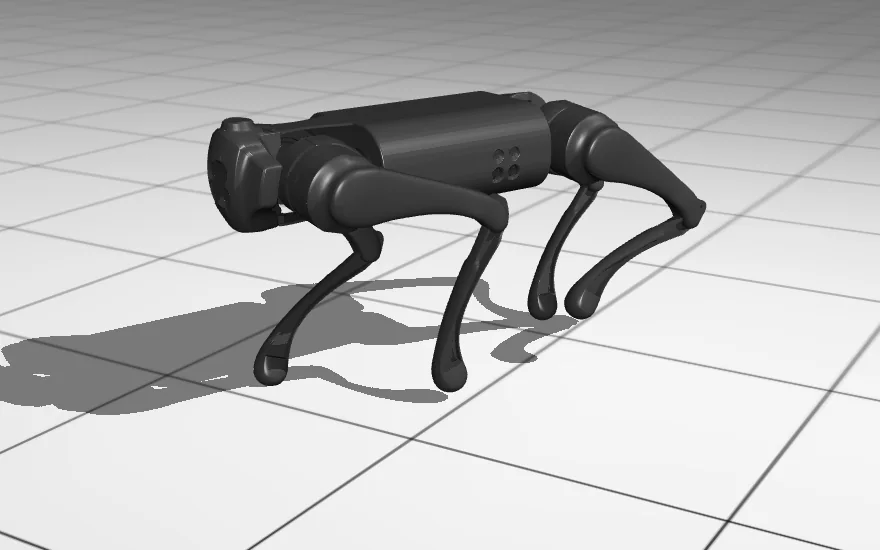 0.76 s
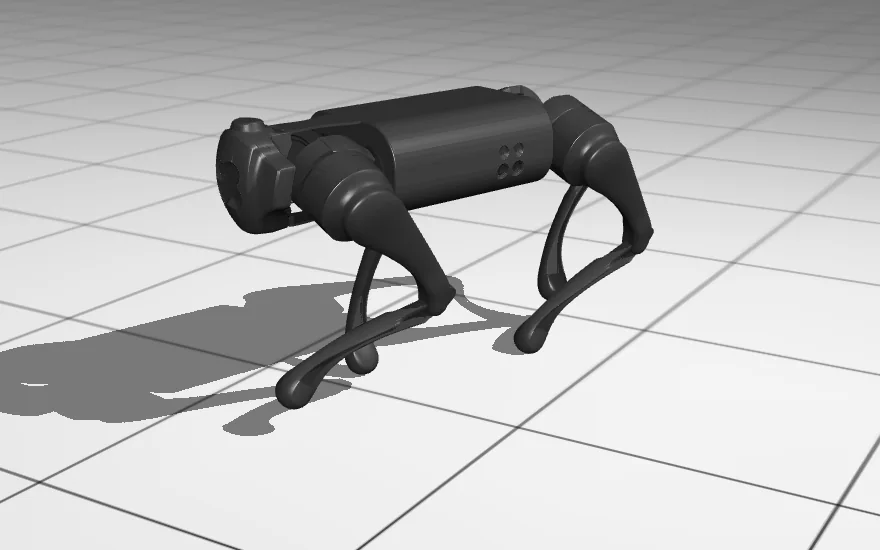 0.86 s
Found by BreakPoint
40 ms latency · 13% sensor dropout · 4° slope
Falls in 0.86 s
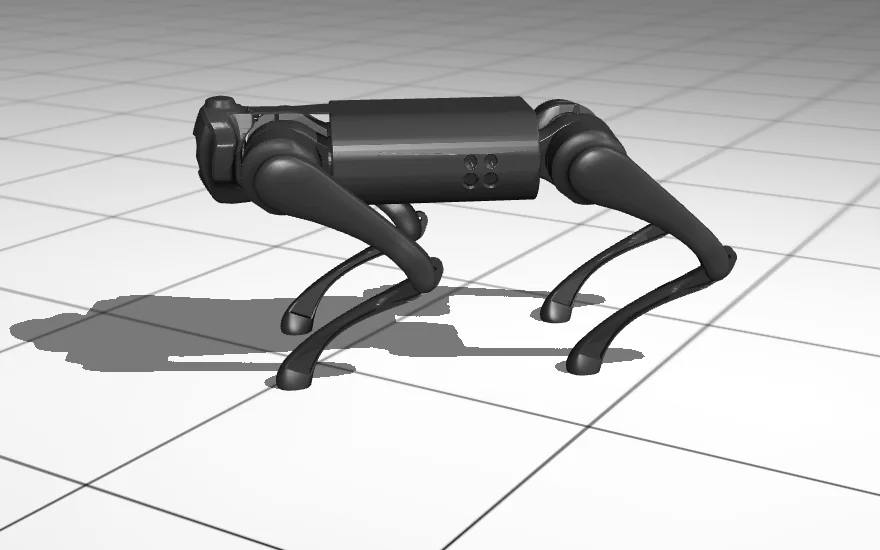 0.00 s
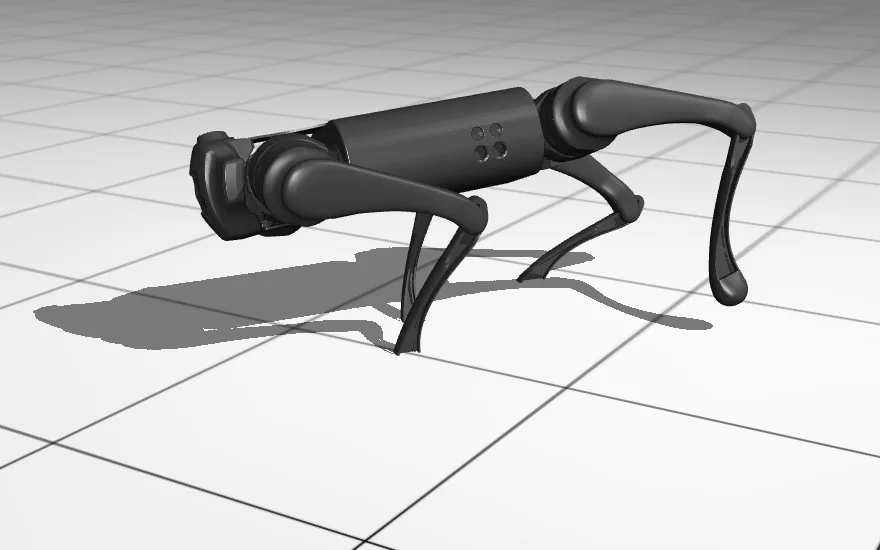 0.56 s
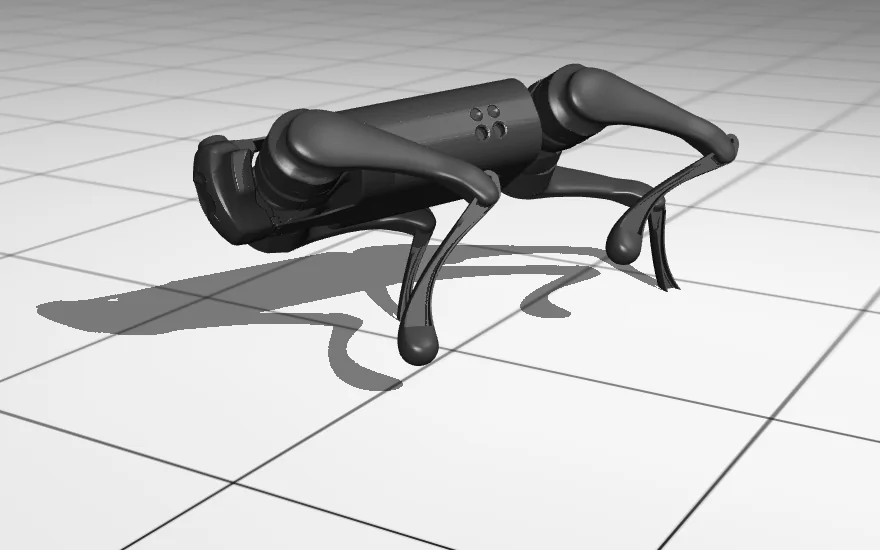 0.76 s
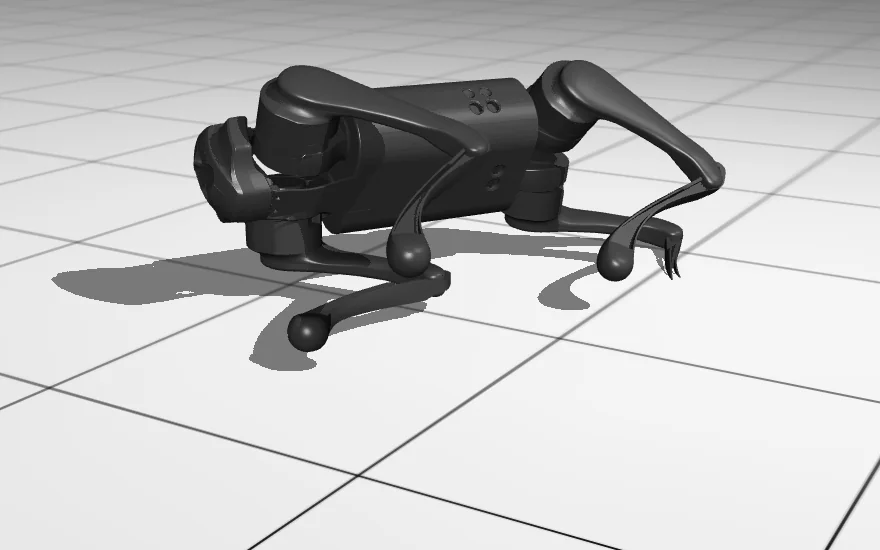 0.86 s
How it works
- 01
Search
Changes friction, mass, latency, sensor noise and more across thousands of runs at once on a GPU.
- 02
Verify
Replays each fall exactly, then runs it again in a second physics engine.
- 03
Gate
Compares every new checkpoint with the current one in CI and fails the build if it got worse.
Results so far (simulation)
2×
as many falls found in realistic conditions as random sampling, same compute
1%
false alarm rate for the CI check. A simple any-regression rule fails 50% of unchanged builds
~50%
fewer falls than standard domain randomization after retraining, on Go1 and Spot
Team
Vihan Aggarwal
CEO and CGO
MIT CSAIL · IEEE Best Paper, AIIoT 2026
Subhi Stephan
CTO and CMO
Duke BME and ECE · MIT research
Backed by
Contact
If you train policies for legged robots, we'd like to run BreakPoint on one of yours.